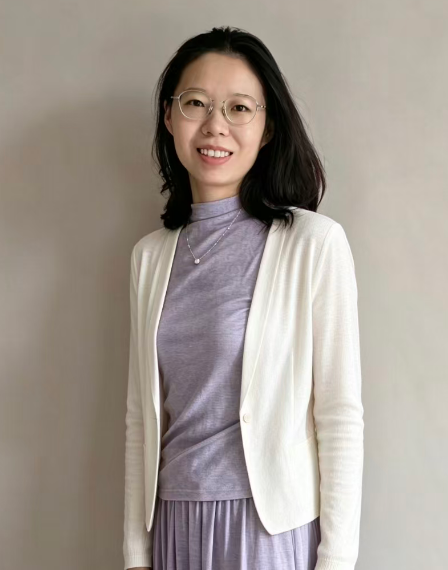
范彦丽,女,1995年出生,中共党员、工学博士,物理与电子工程学院讲师。
一、教育经历
2021年9月—2025年6月,华南理工大学自动化科学与工程学院,工学博士
2018年9月—2021年6月,辽宁工业大学电气工程学院,工学硕士
2014年9月—2018年6月,榆林学院能源工程学院,工学学士
二、主讲课程
《现代控制理论》等课程
三、研究方向
自适应智能控制
四、代表性科研成果
(一)科研项目
主持陕西省教育厅项目1项
(二)代表性科研论文
[1] Fan Y L, Yang C G, Li B, Li Y M. Neuro-Adaptive-Based Fixed-Time Composite Learning Control for Manipulators with Given Transient Performance. IEEE Transactions on Cybernetics, 2024, 54(12): 7668-7680.
[2] Fan Y L, Yang C G, Zhan H, Li Y M. Neuro-Adaptive-Based Predefined-Time Smooth Control for Manipulators with Disturbance. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2024, 54(8): 4605-4616.
[3] Fan Y L, Zhan H, Li Y M, Yang C G. A Predefined Time Constrained Adaptive Fuzzy Control Method with Singularity-Free Switching for Uncertain Robots. IEEE Transactions on Fuzzy Systems, 2024, 35(5): 2650-2662.
[4] Fan Y L, Yang C G, Li Y M. Fixed-Time Neuro-Optimal Adaptive Control with Input Saturation for Uncertain Robots. IEEE Internet of Things Journal, 2024, 11(17): 28906-28917.
[6] Fan Y L, Huang H Q, Yang C G. Fixed-Time Incremental Neural Control for Manipulator Based on Composite Learning with Input Saturation. Actuators, 2022, 54(12): 373.
[5] Li Y M, Fan Y L, Li K W, Liu W, Tong S. Adaptive optimized backstepping control-based RL algorithm for stochastic nonlinear systems with state constraints and its application. IEEE Transactions on Cybernetics. 2021, 52(10):10542-10555.